Learning Safe-by-Design Neural Network Controllers
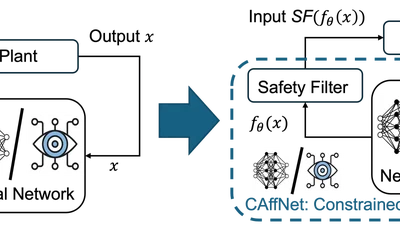
Safety filters constructed from control barrier functions (CBFs) are commonly appended to pre-trained neural network controllers to enforce safety requirements. However, this …
yang-zhao
Safety filters constructed from control barrier functions (CBFs) are commonly appended to pre-trained neural network controllers to enforce safety requirements. However, this …
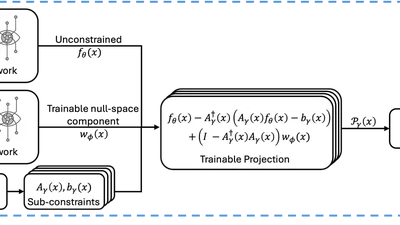
We present a novel framework for embedding hard constraint satisfaction into neural network (NN) architectures, specifically feedforward neural networks and transformers, with …

This letter presents an output-feedback tube-based model predictive control (MPC) framework for linear sampled-data control systems subject to external disturbances and non-convex …
The rapid advancements in air mobility vehicles is paving the way for air taxis to become a viable mode of public transportation. The next technological frontier for air taxis is …
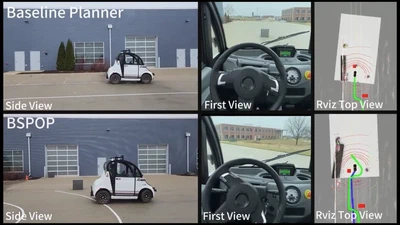
For the cascaded planning and control modules implemented for robot navigation, the frequency gap between the planner and controller has received limited attention. In this study, …

Perception, Planning, and Control form the essential components of autonomy in advanced air mobility. This work advances the holistic integration of these components to enhance the …